Manipulator Jacobian from the elementary transform sequence
2018 · 7 pages · 245 kB
How to compute a serial-link manipulator's Jacobian directly from its elementary transform sequence (ETS), without first converting to Denavit-Hartenberg parameters.
Technical notes, papers, books and historical documents, free to download.
Short technical notes, tutorials and derivations.
2018 · 7 pages · 245 kB
How to compute a serial-link manipulator's Jacobian directly from its elementary transform sequence (ETS), without first converting to Denavit-Hartenberg parameters.
2018 · 3 pages · 138 kB
Derives the Jacobian needed to extend the EKF state vector when a new landmark is discovered, for both the map-making and the full SLAM cases.
2018 · 4 pages · 157 kB
Several ways to solve the equation a cos θ + b sin θ = c, which turns up again and again in inverse kinematics.
Also: MATLAB live script (5 kB)
2018 · 18 pages · 789 kB
A readable tutorial on the Universal Robot Description Format (URDF) used across ROS, starting from XML basics and working through examples in MATLAB.
Also: example files (12 kB)
2018 · 8 pages · 112 kB
A tutorial on XML and on MATLAB's built-in support for parsing it, filling gaps in the official documentation.
Also: example files (6 kB)
2016 · 6 pages · 185 kB
A tutorial introduction to binary classifiers, the confusion matrix, and how precision-recall curves are constructed and interpreted.
2015 · 8 pages · 386 kB
A chronology of what happened to René Descartes' remains after his death in Stockholm in 1650, summarised from Russell Shorto's book Descartes' Bones.
2014 · 14 pages · 392 kB
The physical meaning of Denavit-Hartenberg parameters for common robot arm configurations, with consistent diagrams and parameter tables.
2014 · 6 pages · 926 kB
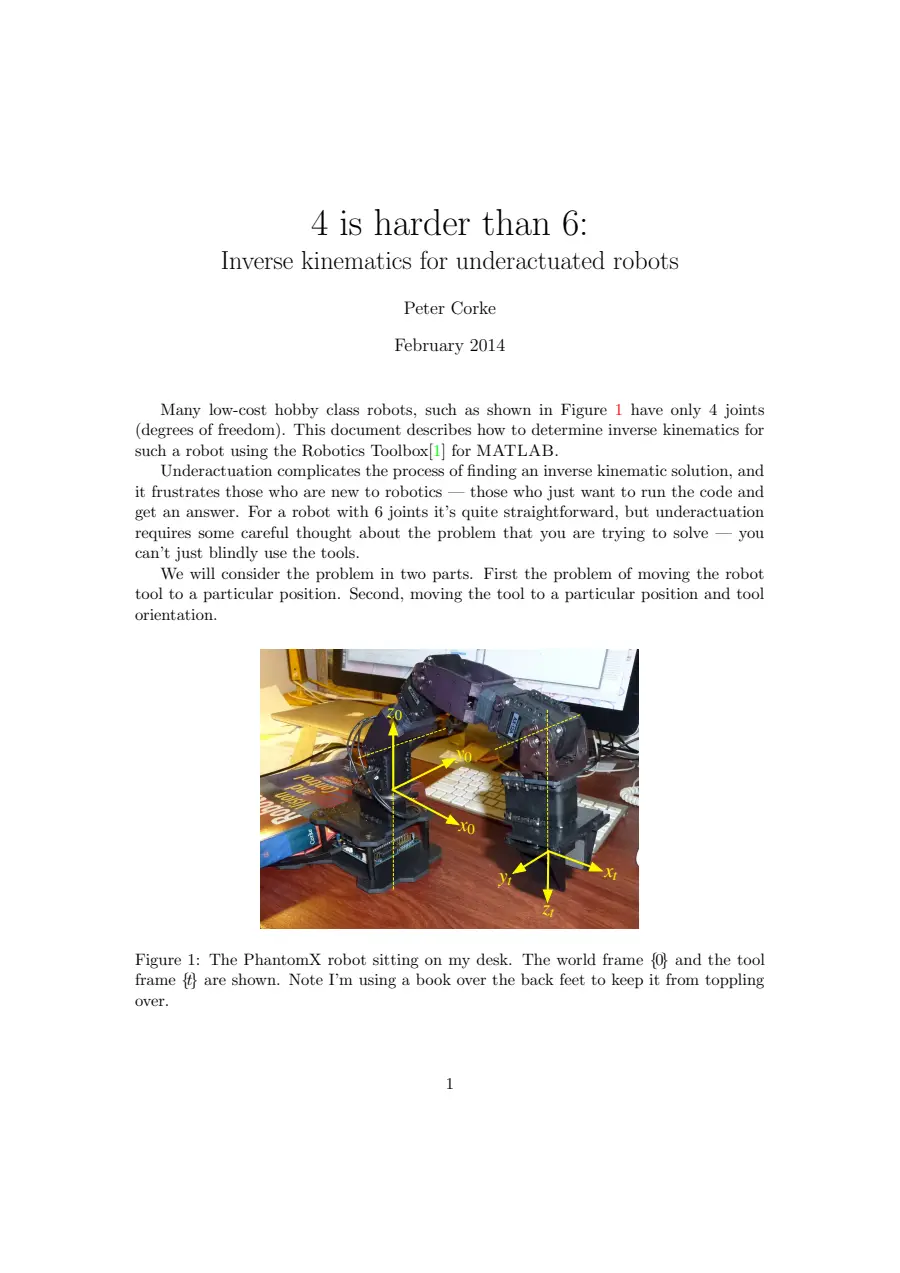
Why inverse kinematics for a 4-joint hobby robot is harder than for a 6-joint industrial arm, and how to solve it with the Robotics Toolbox for MATLAB.
2013 · 9 pages · 890 kB
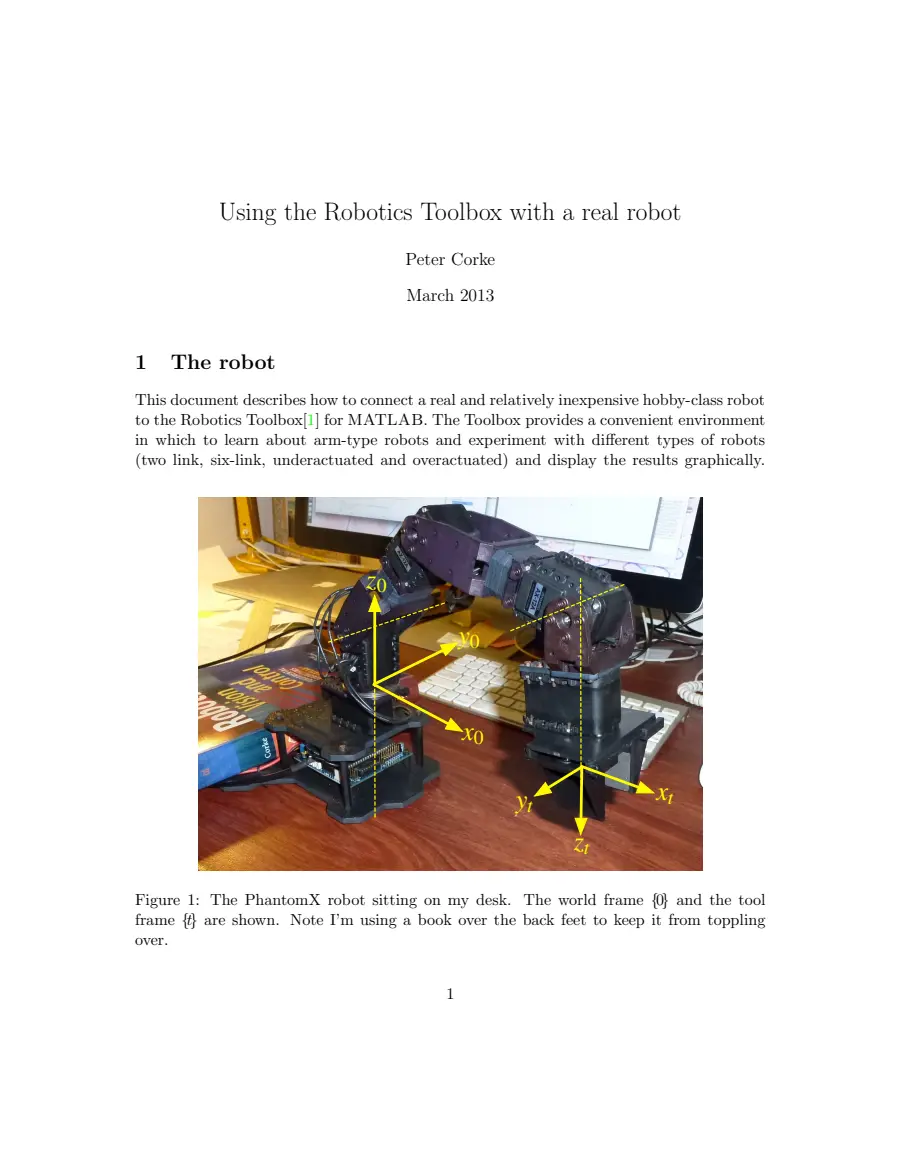
How to connect an inexpensive hobby-class robot arm (the PhantomX) to the Robotics Toolbox for MATLAB and drive it from the Toolbox.
Out-of-print books and supporting material for Robotics, Vision & Control.
2017 · 95 pages · 941 kB
Worked solutions to the exercises in Robotics, Vision & Control, second edition.
Also: MATLAB live scripts · figures (EPS) · figures (SVG)
1996 · 378 pages · 3.1 MB
The 'Blue Book': a monograph on high-performance visual servo control of robot manipulators, from the CSIRO Division of Manufacturing Technology. Out of print, free to download.
Conference papers and technical reports.
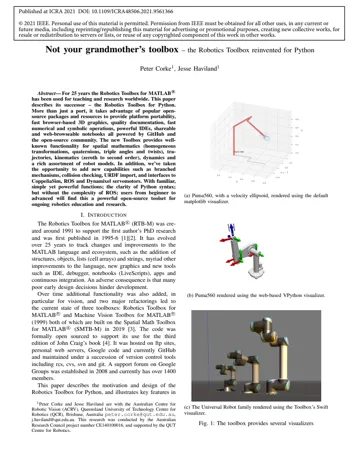
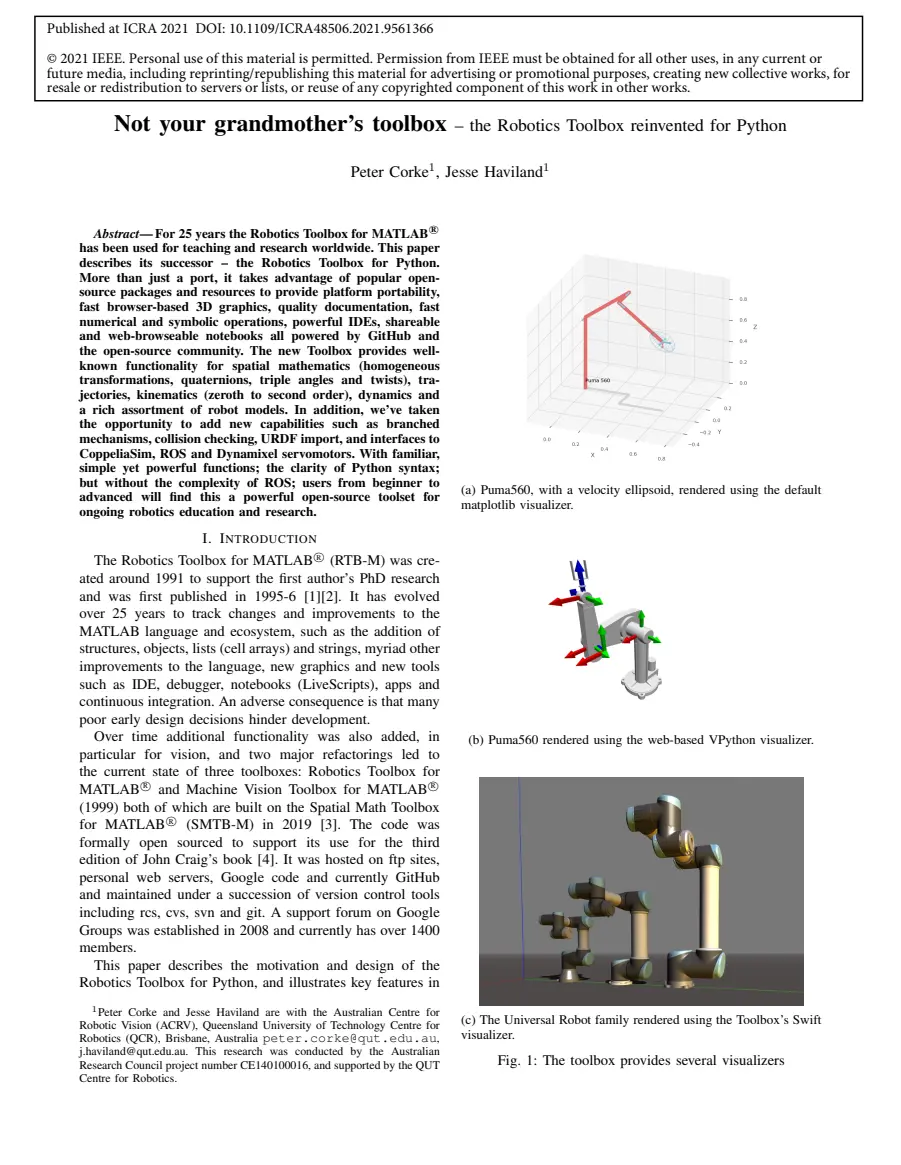
2021 · 7 pages · 587 kB
ICRA 2021 paper describing the Robotics Toolbox for Python, the successor to the Robotics Toolbox for MATLAB, and how it builds on open-source tools for portability, 3D graphics and documentation.
CSIRO Division of Manufacturing Technology · MTM-226 · 1994 · 54 pages · 27.2 MB
A detailed technical description of the Puma 560 robot's digital servo system: the arm interface board, servo card hardware and firmware, and the axis electromechanical dynamics. Scanned.
Reports and documents of historical interest in robotics.
Stanford AI Lab · AIM-177 (STAN-CS-72-311) · 1972 · 96 pages · 8.7 MB
Richard Paul's 1972 Stanford AI Laboratory report (AIM-177), a foundational work on manipulator kinematics, trajectory generation and servo control. Scanned NTIS copy.
Approved for public release; distribution unlimited (NTIS)